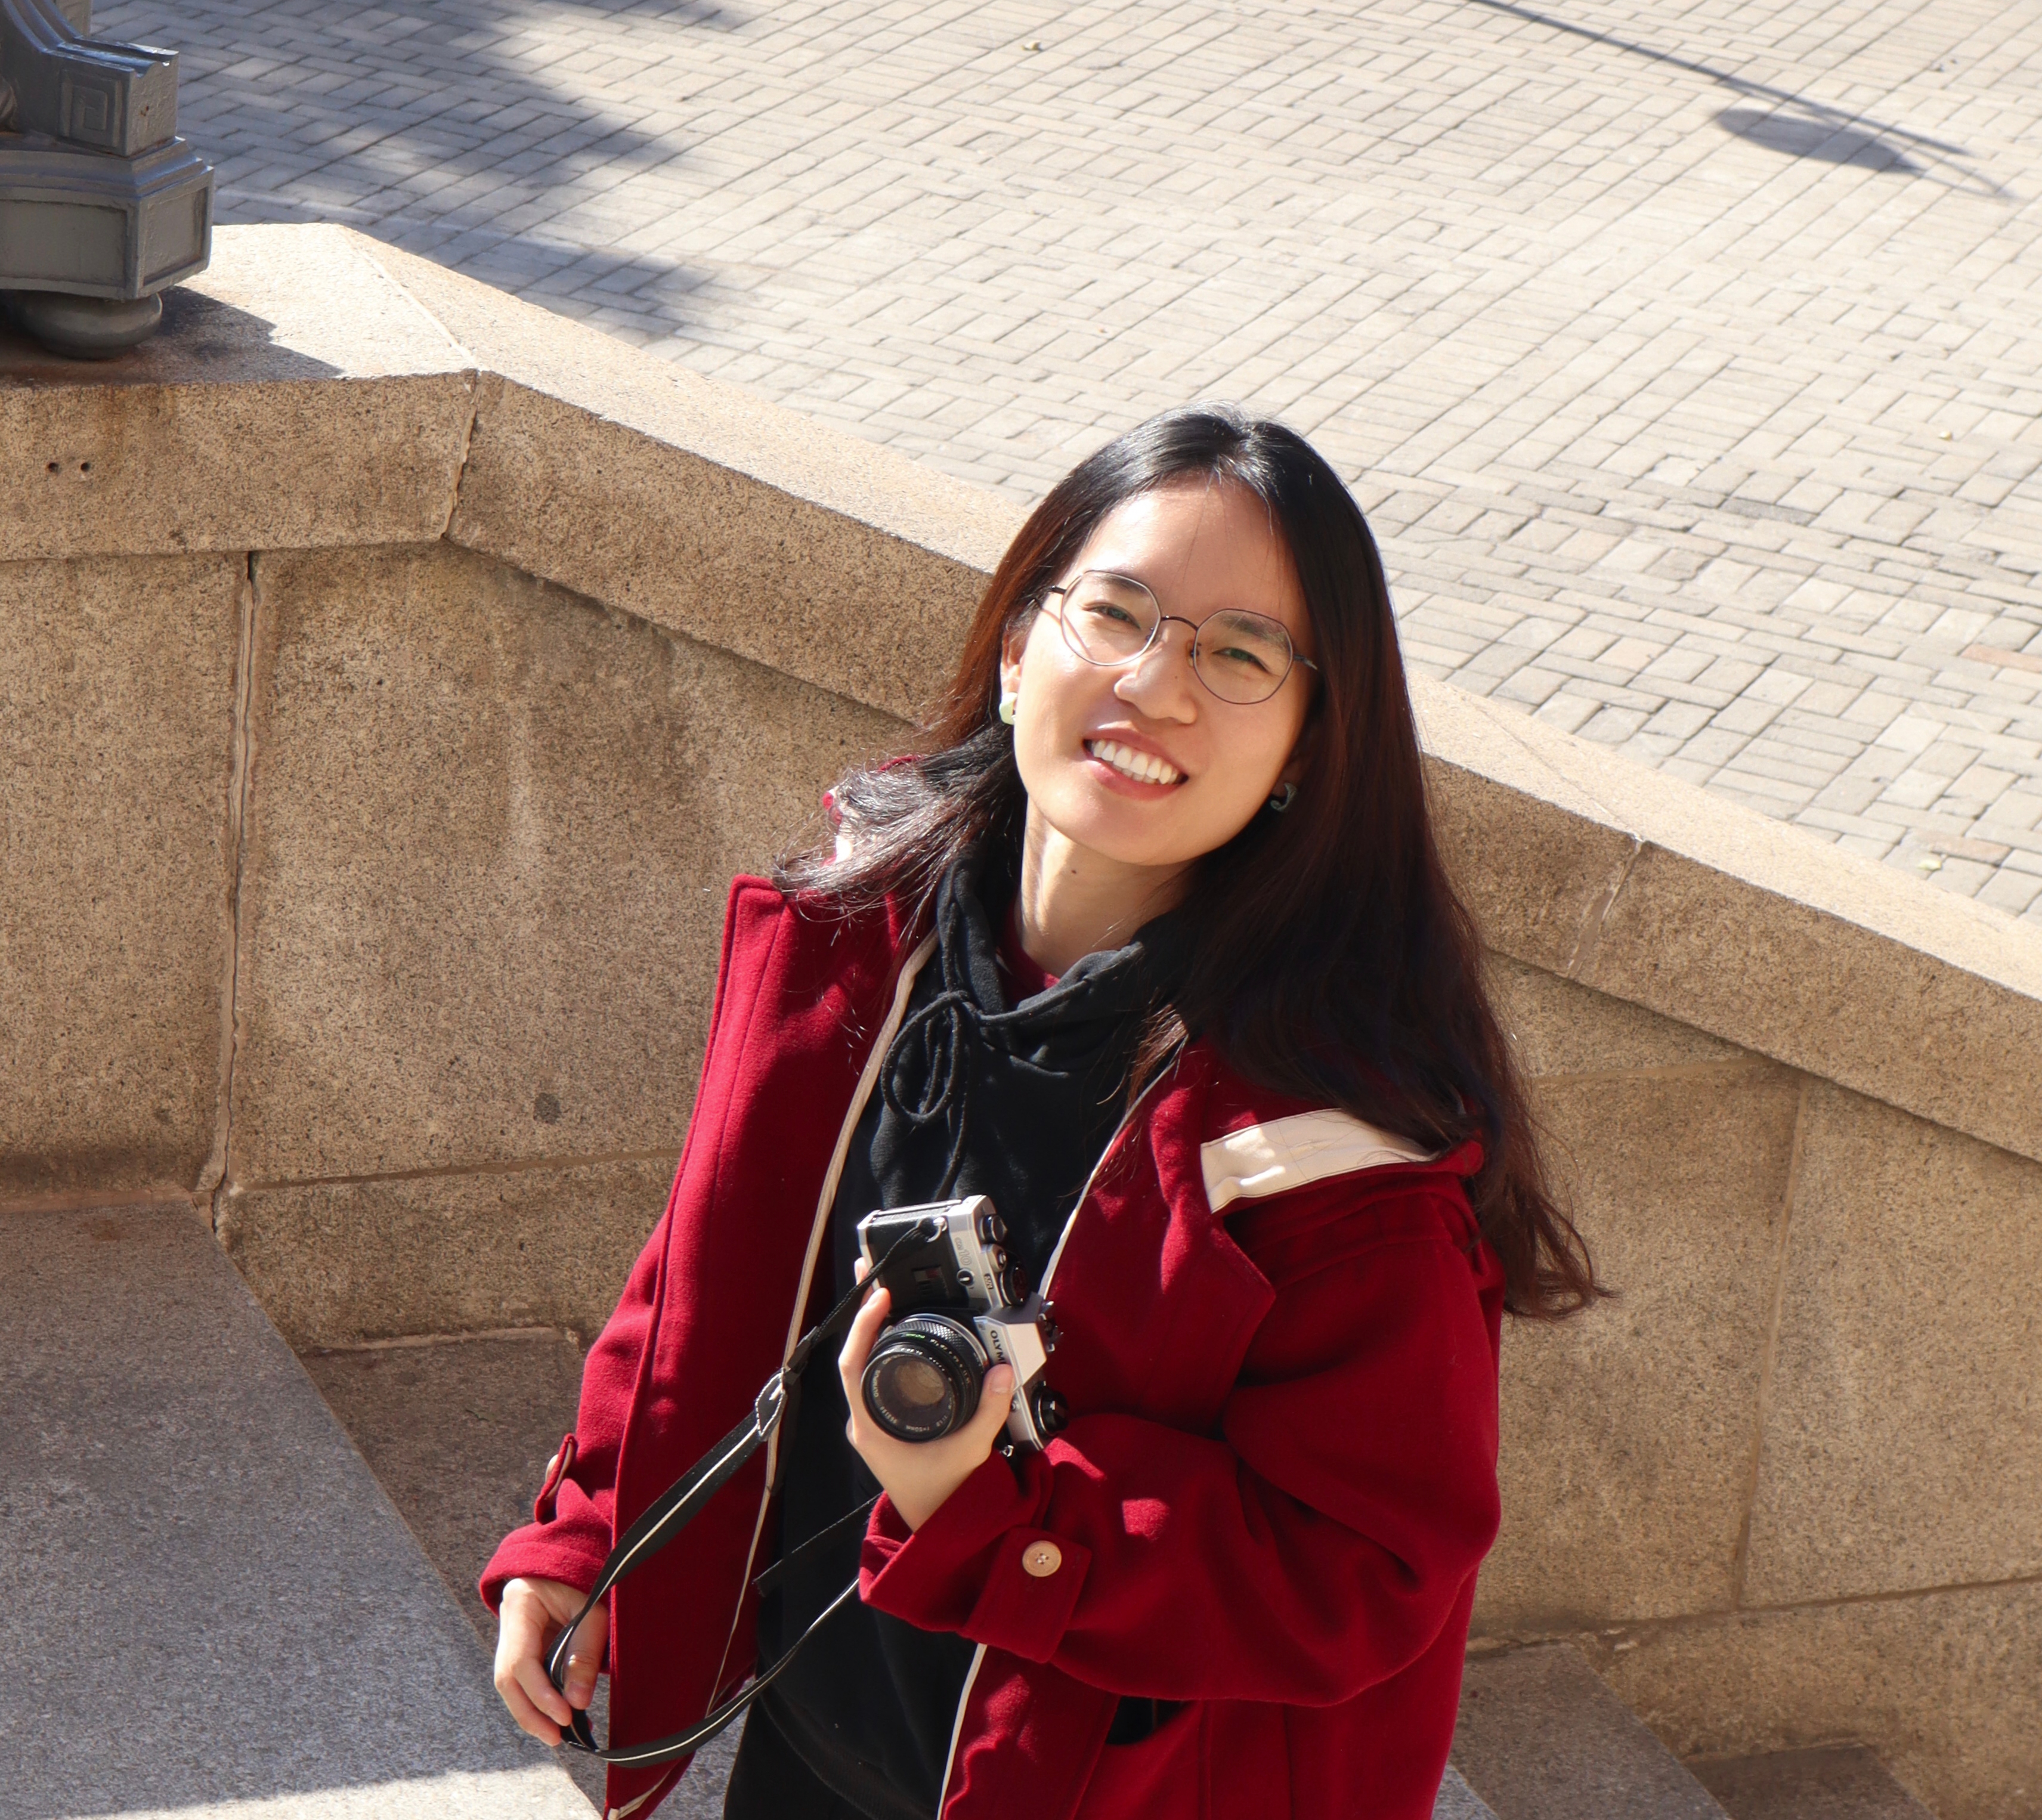
 Le Qiu
PhD Student
Le is a PhD student working at the intersection of optimization, control theory, and learning-based control for robotics. Their research aims to develop reliable, adaptive, and generalizable robot autonomy.